
Brahma H7
The actual 3D design of the flight controller. Turn it over and look at it from any side.
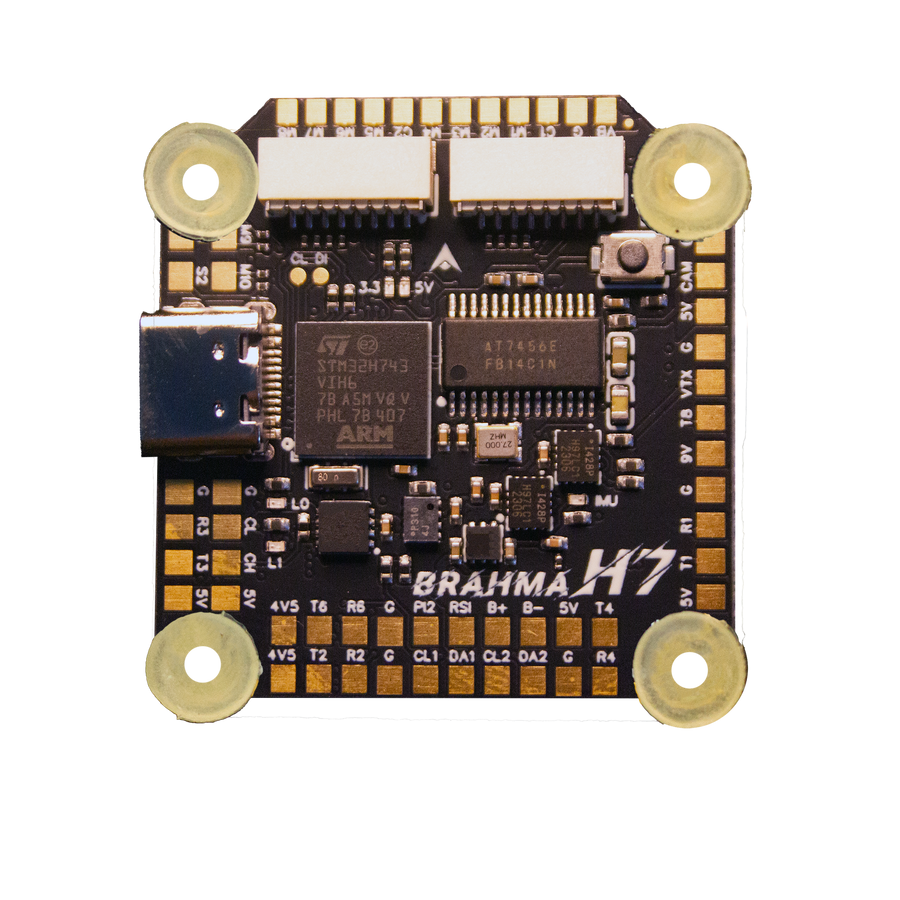
Four screws.
M3 screws come up through the frame on the standard 30.5 × 30.5 mm pattern. The same pattern on every Brahma and Vishnu.
Grommets first.
A soft TPE grommet presses into each mounting hole, so frame vibration stays out of the gyros. We injection-mould them ourselves, and eight come with every stack.
Vishnu, then Brahma.
The ESC slides down the screws first. The flight controller sits on top.
Four nuts. One cable.
An 8-pin cable links the two boards. Tighten four nuts, close the frame, and you are wired.
Same stack.
Any size.
It drops into 5, 7 and 10-inch frames, and onto a 650-class machine with our stack holder. The gold circles are the props each one swings.
Take off.
The 650-class machine lifts off on the same Brahma and Vishnu stack, with an extinguisher ball underneath.
Straight to the fire.
No road, no ladder, no one walking into the heat.
Drop. Out.
The ball goes in from above and bursts on the flames.
Now give it a mind.
Pair the Brahma H7 with an onboard computer, a Raspberry Pi, Radxa or Jetson, over UART and MAVLink. The same airframe starts deciding for itself.
Picks up on its own.
It finds the supply crate, lands over it and locks on. No pilot on the sticks.
Finds who needs it.
Vision scans the flood roof by roof until it finds people waiting.
Delivers.
Food and medicine, lowered on a line onto the rooftop.
Home. Fresh battery.
It flies back to the dock, sheds the spent pack and takes a charged one.
And goes again.
Sortie after sortie, for as long as there are people to reach.
Same brain.
New wings.
Move the Brahma H7 into a VTOL. It lifts off like a multirotor and cruises like a plane, so it can reach places a multirotor never could.
No GPS.
It still gets there.
Drop a pin far away. With a camera and visual-inertial odometry (VIO) on the companion computer, it holds its course when GPS is jammed or lost, scans the ground in 3D and sends the model home.
Illustration. Brahma H7 runs ArduPilot and PX4 and talks to a companion computer over MAVLink; the autonomy is built on top by the integrator.
Every part,
up close.
Scroll to fly across the real board model.
STM32H743
480MHz Cortex-M7 class processing for fast loops, heavy filtering and autonomous flight.
USB Type-C
Configure, flash and tune over a single modern connector.
Dual ICM42688P
Two gyroscopes for cleaner attitude data, even on a high-vibration frame.
10 motors
Two plug-in ESC ports for M1 to M8, plus solder pads for M9 and M10.
S1 and S2
Ten motors connected and there is still room: two servo outputs for a gimbal, a drop or a tilt.
CAN port
CH and CL pads for CAN GPS, ESCs and sensors.
Two GPS + compass
Two I²C buses, so two GPS and compass modules can run side by side.
Switchable 9V
A 9V rail you can switch from the radio, with an extra PINIO pad to switch something else.
The other side.
Blackbox logging to microSD, and the power stage that feeds everything on board.
Digital VTX port
One plug for DJI, Walksnail and other digital video systems. No soldering.
3A at 5V. 3A at 9V.
Two regulators on board, each good for 3 amps.
A full telemetry port
A UART with RTS and CTS flow control, for a telemetry radio that never drops a byte.
SPI on pads
SCK, MISO, MOSI and two chip selects, broken out for your own sensors.
Every part chosen for ultimate performance.
Chips, connectors, crystals, capacitors. Each one picked for the job, then placed exactly where the design says.
Ready to fly.
The Brahma H7, assembled from its own 3D design.
Brahma H7 specifications
A 480MHz STM32H743 flight controller for Betaflight, INAV, ArduPilot and PX4. Ten motor outputs, seven UARTs, CAN, dual gyroscopes and a plug-and-play digital VTX port, on a standard 30.5 × 30.5 mm mount.
| Processor | STM32H743, 480MHz |
|---|---|
| Gyroscopes | Dual ICM42688 |
| Barometer | DPS310 |
| On-screen display | AT7456E |
| Blackbox | microSD card slot |
| USB | Type-C |
| Firmware | Ships with ArduPilot or PX4 (your choice at order). Betaflight and INAV files are on our downloads page. |
| Power input | 2S-6S LiPo or Li-ion |
| UARTs | 7 (UART7 with RTS/CTS flow control) |
| I²C | 2 buses, for two GPS + compass modules |
| CAN | Yes, CH and CL pads |
| SPI | 2 breakouts |
| Motor outputs | 10: two plug-in ESC ports (M1–M4, M5–M8) and solder pads for M9, M10 |
| PWM outputs | 13 in total (10 motors, 2 servos, 1 LED) |
| 5V output | 3A across 9 pad groups |
| 9V output | 3A, switchable on/off from the radio |
| 3.3V output | 1A, for compasses and sensors |
| 4.5V output | Powered over USB, for the receiver while configuring |
| Digital VTX | Plug-and-play port (DJI, Walksnail and others) |
| Extras | Relay PINIO, 2 NeoPixel LED pads, RSSI, SBUS, SmartPort, buzzer pads |
| Operating temperature | −20 °C to 70 °C |
| Mounting | 30.5 × 30.5 mm, 4 mm holes |
| Dimensions | 37 × 35.5 × 8 mm |
| Weight | 9 g |
| Made in | Designed and manufactured in India (Bally, West Bengal) |
Book your Brahma H7
Message us on WhatsApp. We reply with availability, price and delivery time, and help you pick the right parts for your build.


Brahma H7 user manual
Point at any label to see the wire and the part it belongs to. Step through the flashing guides. Zoom in on anything.
Point at a label or a wire to trace it. Click to keep it lit. Double-click to zoom.
Read the Brahma H7 manual as text
BRAHMA H7: Specifications 1/3
| Product Name | Darkmatter® Brahma H7 |
|---|---|
| Product Category | Flight Controller |
| Processor (MCU) | STM32H743VIT6 ARM (480MHz) |
| Gyroscope (IMU) | DUAL ICM42688 |
| Barometer | DPS310 |
| On-Screen Display | AT7456E |
| Blackbox | SD CARD |
| USB Port Type | Type-C |
| Supported Flight Controller Firmware | BetaFlight (Default), iNav, Ardupilot, PX4 |
| Power Input | 2S-6S LiPo or Li-ion |
| Mounting | 30.5 X 30.5mm (4mm hole size) |
| Dimensions | 37mm (L) x 35.5 mm(W) x 8mm(H) |
| Weight | 9g |
BRAHMA H7: Specifications 2/3
| 5V Output | 9 groups of 5V output. The total current load is 3A. |
|---|---|
| 9V Output | 1 groups of 9V output, one +9V pad on front side. The total current load is 3A. Switchable On/OFF |
| 4v5 Output | 2 4.5V output, 500mA while connected from USB to connect receiver or other peripherals, Standard 3A on Battery |
| 3.3V Output | Supported. Up to 1A current load. |
| LED PADS | 2X NEO PIXEL LED PAD Groups |
| Buzzer | BZ+ and BZ- pad used for 5V Active Piezo Buzzer |
| Motors Supported | 10 Motors - 2X ESC Plug & Play [M1-M4] [M5-M8] - 2x Solder Pads M9-M10 |
| ESC Signal | M1 - M10 on top side |
| Digital Vtx | Plug and Play Port |
| Switchable VTX Power | You can turn on and off the VTX 9V supply from your RC to get faster GPS lock |
| Total PWM Outputs | 13 [10 Motors][2 Servo][1 LED] |
| CAN PORT | Yes |
| SPI BREAKOUTS | 2x SPI BREAKOUTS |
BRAHMA H7: Specifications 3/3
| BOOT Button | Press and hold BOOT button and power the FC on at the same time will force the FC to enter DFU mode, this is for firmware flashing. |
|---|---|
| RSSI Input | Supported. Named as RSI on the front side. |
| SmartPort | Use any TX pad of UART for the SmartPort feature. |
| UART | 7 sets (UART 1,2,3,4,6,7,8) |
| UART FLOW CONTROL | UART 7 SUPPORTS FLOW CONTROL CTS and RTS signaling |
| ADC | 6 ADC |
| Pin IO | 2x Pin IO for Relays, etc. |
| I2C | 2x Supported. I2C1 & I2C2 - SDA & SCL pads on front side. Used for magnetometer, sonar, etc. |
| OPERATING TEMPERATURE | -20°C TO 70°C.. |
| COUNTRY OF ORIGIN | DESIGNED AND MANUFACTURED IN INDIA |
DIMENSIONS
Front · Back · 30.5MM · 4MM · 37MM · 35.5 MM · 30MM · Side · 8MM · 1.6MM
Flight Controller Layout
MCU STM32H743 · OSD Chip · Gyro 1 – ICM42688P · Baro – DPS310/DPS368 · Boot Button · M4-M3-M2-M1-Rx8-C1-GND-VB · Type C Port · SERVO 1 · CAN PORT · UART 4 · Buzzer · SOLDER PADS-> M8-M7-M6-M5-C2-M4-M3-M2-M1-C1-G-VB · ADC-1 · UART-7(with Flow Control) · MICRO SD SLOT · LED 2 · DIGITAL VTX PLUG AND PLAY UART 4 R3 <> RX SBUS · SPI-3 BREAKOUT · ANALOG CAMERA · UART 7 FLOW CONTROL PADS · VTX + UART 8 · UART 3 · MOTOR 9 · I2C 1 (COMPASS) · UART 1 · M8-M7-M6-M5-Rx7-C2-GND-VB · SERVO 2 · Gyro 2 – ICM42688P · I2C 2 · ADC RSSI PIN · PIN IO · UART 6 ( Radio Receiver ) · UART 2 (GPS) · MOTOR 10 · ADC-2 · LED 1 · CS1 · CS2 · *ADC-1 > PA4 - Can be used as a external 2nd Battery ADC upto 6S ( 1 : 11 voltage ratio ) · *ADC-2 > PC4 - Can be used as a external ADC for Airspeed Sensor. · *C1 -> PC1 - ADC Current Esc-1 *C2 -> PA7 - ADC Current Esc-2 *VB -> Voltage Battery(7.4v-26v)6S · R3 G R4 T4 G 9V · 8Pin Conn -> 4in1 ESC-1 · 8Pin Conn -> 4in1 ESC-2
Flight Controller – STANDARD CONNECTION PROTOCOL
GPS WITH MAG 1 · FPV CAM · 5V · SCL · SDA · B+ · B- · CAM · RX · 9V · 5V ACTIVE Buzzer · 4IN1 ESC 1 · GPS WITH MAG 2 · CAN DEVICE · CL · CH · VTX · 4IN1 ESC 2 · DARKLABS COSMOS LED DESIGNED BY AMIT · ELRS RX · SERVO 1 · SERVO 2 · RELAY · P+ · P- · LOAD · PMW3901 OPTICAL FLOW · CS · SCK · MOS · MIS · ADC1 - Can be used as a external 2nd Battery ADC upto 6S. *1 : 11 voltage division. · ADC2 - Can be used as a external ADC for Airspeed Sensor. · M4-M3-M2-M1-Rx8-C1-GND-VB · M8-M7-M6-M5-Rx7-C2-GND-VB · *If using DJI Air Unit with 6P connector, then 2nd GPS must be connected to different UART(like UART-1 or UART-3)
DUAL 4 in 1 ESC Plug and Play Connection
DUAL 4 in 1 ESC Plug and Play Connection · CURRENT ADC 1 · MOTOR 1 · MOTOR 2 · MOTOR 3 · MOTOR 4 · GROUND · VOLTAGE · TELEMETRY (RX8) · Motor 2 · Motor 4 · Motor 3 · Motor 1 · CURRENT ADC 2 · MOTOR 5 · MOTOR 6 · MOTOR 7 · MOTOR 8 · VOLTAGE · TELEMETRY (RX7) · Motor 6 · Motor 8 · Motor 7 · Motor 5 · ESC1 · ESC2 · **IF CONNECTING SEPARATE BATTERY TO TWO ESC, CUT WIRE FROM THE 1ST PIN OF THE 2ND 4IN1 ESC CONNECTOR**. IF SAME BATTERY IS SHARED AMONG ESC, THIS STEP CAN BE SKIPPED. · 8 7 6 5 4 3 2 1
DUAL 4 in 1 ESC Direct Soldering Connection
Motor 6 · Motor 8 · Motor 7 · Motor 5 · CURRENT · MOTOR 8 · MOTOR 7 · MOTOR 6 · MOTOR 5 · GROUND · VOLTAGE · Motor 2 · Motor 4 · Motor 3 · Motor 1 · MOTOR 4 · MOTOR 3 · MOTOR 2 · MOTOR 1 · BATTERY + · BATTERY - · PLEASE USE COMMON BAT+ BAT- IF YOU ARE USING TWO BATTERIES, PLEASE DON’T POWER THE TWO ESCS WITH TWO BATTERIES SEPARATELY, KINDLY BRIDGE THEM. · ⚠️
10 SINGLE ESC CONNECTION
SINGLE ESC 7 · SINGLE ESC 8 · SINGLE ESC 1 · BAT - · 5V OUT · BAT + · SIGNAL · SIG GND · SINGLE ESC 2 · SINGLE ESC 3 · SINGLE ESC 4 · SINGLE ESC 5 · SINGLE ESC 6 · SINGLE ESC 9 · SINGLE ESC 10 · BATTERY
CONNECT BRAHMA H7 WITH IBUS RECEIVER
IBUS RECEIVER · *IF USING BETAFLIGHT KINDLY REFLASH WITH IBUS PROTOCOL SELECTED AND THEN TURN ON Serial Rx ON UART 6
Flight Controller – Package Contents
Darkmatter – BRAHMA H7 Flight Controller x 1 · SH 1.0mm 30mm-length 8pin Cable(for FC-ESC connection) x 2
HOW TO FLASH PX4 ON BRAHMA H7 (1/3)
- PRESS AND HOLD THE BOOT BUTTON and connect to PC and open STM32 Cube Programmer
- Click on the refresh button to get your board recognised
- 3a) Open the second menu item -> Erasing & Programming
- Open the First menu item
- Click on Connect
- Click on Open File and load the Firmware
- Click on the download button to start flashing the board with the firmware and wait till flashing is done
HOW TO FLASH PX4 ON BRAHMA H7 (2/3)
- Open the QGroundControl application
- Open Vehicle Configuration
- Click on Firmware and then connect Brahma H7 to your PC
- Select PX4 Pro
- Click on Advanced Settings
- Select Custom Firmware File
- Click on OK to proceed to firmware file selection
- Select the Darkmatter Brahma H7 PX4 firmware file
- Wait for Firmware Flashing to Complete and Enjoy :)
HOW TO FLASH PX4 ON BRAHMA H7 (3/3)
WANT TO MAKE CUSTOM CHANGES TO THE FIRMWARE? · SCAN TO DOWNLOAD THE SOURCE CODE ALONG WITH THE FOLDER STRUCTURE TO CREATE CUSTOM PX4 FIRMWARE FOR Darkmatter® Brahma H7 BASED ON YOUR NEEDS · https://docs.px4.io/main/en/development/development.html · PX4 OFFICIAL DEV GUIDE :
HOW TO FLASH ARDUPILOT ON BRAHMA H7 (1/2)
- PRESS AND HOLD THE BOOT BUTTON and connect to PC and open STM32 Cube Programmer
- CLICK ON CONNECT
- Open the second menu item -> Erasing & Programming
- Before flashing, we need to do Full Chip Erase.
- Open the Brahma H7 Arducopter with bl from your PC.
- Start Programming and wait till the firmware has flashed and then open Mission Planner
HOW TO FLASH ARDUPILOT ON BRAHMA H7 (2/2)
- Open the Mission Planner application
- While connecting please select the MAVLink COM port to connect to Brahma H7
HOW TO CONNECT HERELINK WITH BRAHMA H7
Herelink SBUS Herelink ‘S Bus out 1’ to BRAHMA H7 RX6 (Serial 7) Herelink GRD to a BRAHMA H7 GND SERIAL7_PROTOCOL=23 (RCIN) SERIAL7_OPTIONS=3 (SwapTXRX - RX6 becomes TX6). Herelink UART connector Herelink RXD to the BRAHMA H7 TX1 (Serial 2) Herelink TXD to the BRAHMA H7 RX1 (Serial 2) Set SERIAL2_PROTOCOL= 2
HOW TO CONNECT COMPANION COMPUTER (PI) WITH BRAHMA H7
BRAHMA SETUP: Raspberry Pi on UART7 (T7 / R7 pads on the underside). T7 → Pi pin 10 (RXD), R7 → Pi pin 8 (TXD), G → Pi pin 14 (GND). Mission Planner → Full Parameter List: SERIAL1_PROTOCOL = 2 (MAVLink 2), SERIAL1_BAUD = 921 (921600). Official ArduPilot BrahmaH7 build (once released): SERIAL7. COMPANION COMPUTER SETUP: sudo raspi-config → Interface Options → Serial Port: login shell over serial No, serial hardware Yes. Power the Pi from its own 5V BEC (battery → BEC → Pi pins 2 and 6), never from the flight controller. Full guide: Docs → Connect a Raspberry Pi to the Brahma H7.
HOW TO FLASH BETAFLIGHT ON BRAHMA H7 (1/2)
- PRESS AND HOLD THE BOOT BUTTON and connect to PC and open BETAFLIGHT CONFIGURATOR
- ONCE IN DFU CLICK ON UPDATE FIRMWARE
- MAKE SURE FULL CHIP ERASE IS ON
- CLICK ON LOAD FIRMWARE LOCAL
- SCAN TO DOWNLOAD THE HEX FILE AND SELECT THAT
- CLICK ON LOAD FLASH FIRMWARE
- WAIT A BIT FOR THE ERASING AND FLASHING TO COMPLETE
HOW TO FLASH BETAFLIGHT ON BRAHMA H7 (2/2)
- CLICK ON CLOSE
- CLICK ON CLI FROM THE LEFT HAND SIDE MENU
- Enter the following in the command box, and enter save at last to save and reboot
HOW TO FLASH INAV ON BRAHMA H7 (1/2)
- ONCE IN DFU CLICK ON FIRMWARE FLASHER
- PRESS AND HOLD THE BOOT BUTTON and connect to PC and open INAV CONFIGURATOR
- CLICK ON LOAD FIRMWARE LOCAL
- SCAN TO DOWNLOAD THE HEX FILE AND SELECT THAT
- CLICK ON LOAD FLASH FIRMWARE
- WAIT A BIT FOR THE ERASING AND FLASHING TO COMPLETE
HOW TO FLASH INAV ON BRAHMA H7 (2/2)
- SELECT THE TYPE OF CRAFT YOU ARE MAKING
- SELECT THE UART & THE RECEIVER PROTOCOL FOR RX
- SELECT THE UART PORT FOR GPS
• Warranty Period: The BRAHMA H7 Flight Controller comes with a 6-month warranty from the date of purchase. • Proof of Purchase: Please retain and provide a copy of the purchase invoice for warranty claims. • Exclusions: The warranty does not cover any physical damage to the product, including water damage or burning. • Warranty Process: If a claim is made within the warranty period, we will examine the PCB for physical damage. If the product is eligible, we will provide a replacement at no additional cost. Your satisfaction and product performance are our top priorities. For any warranty-related inquiries, please contact us at +91-8017193277.
• Warranty Period: The BRAHMA H7 Flight Controller comes with a 6-month warranty from the date of purchase. • Proof of Purchase: Please retain and provide a copy of the purchase invoice for warranty claims. • Exclusions: The warranty does not cover any physical damage to the product, including water damage or burning. • Warranty Process: If a claim is made within the warranty period, we will examine the PCB for physical damage. If the product is eligible, we will provide a replacement at no additional cost. Your satisfaction and product performance are our top priorities. For any warranty-related inquiries, please contact us at +91-8017193277. · BRAHMA H7 Flight Controller - 6 Months Warranty
- Choosing a selection results in a full page refresh.
- Opens in a new window.