
Stack 460
The actual 3D design of the stack: Brahma F4 on Vishnu 60. Turn it over and look at it from any side.
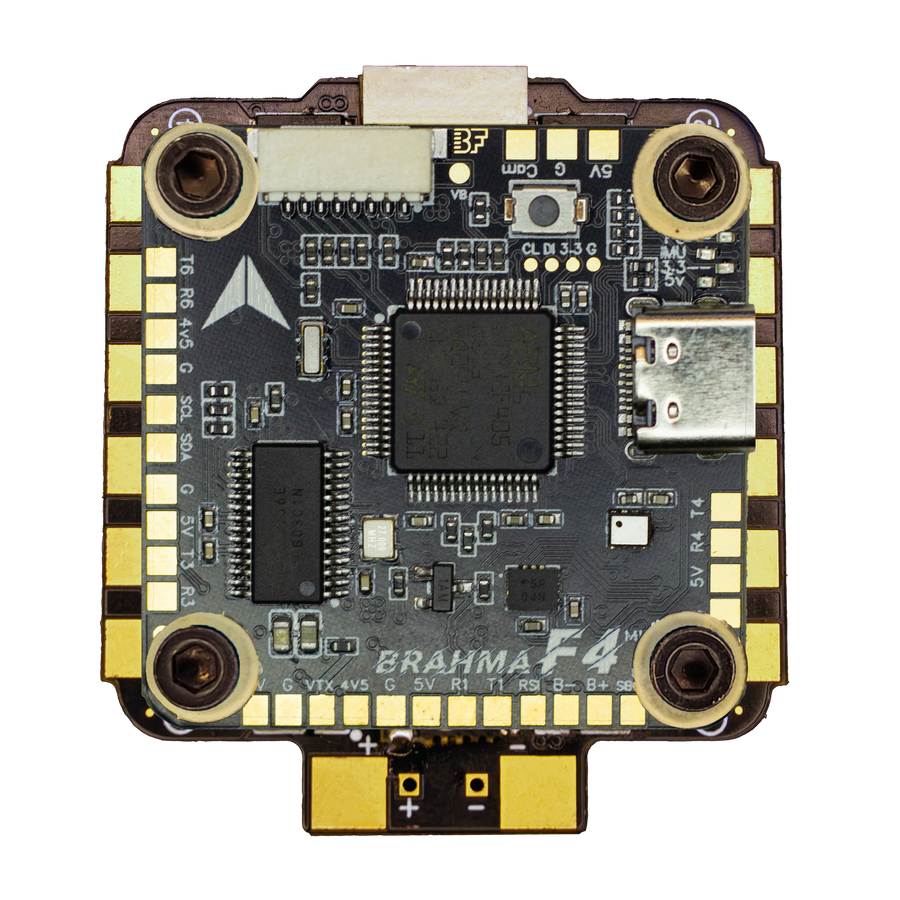
Where the Stack 460 goes.
Four M3 screws come up through the frame on the standard 30.5 × 30.5 mm pattern. Scroll to build it in.
Grommets first.
A soft TPE grommet presses into each mounting hole, so frame vibration stays out of the gyros. We injection-mould them ourselves.
Vishnu, then Brahma.
The Vishnu 60 slides down the screws first. The Brahma F4 sits on top.
Four nuts. One cable.
An 8-pin cable links the two boards. Tighten four nuts, close the frame, and you are wired.
One stack.
Many machines.
One board thinks.
One board moves.
Brahma F4 flight controller + Vishnu 60 4-in-1 ESC on a standard 30.5 × 30.5 mm pattern. Keep scrolling to take it apart.
Flight controller
- MCUSTM32F405
- GyroBMI270
- Ports4 UART · I²C
- MotorsUp to 8
- Logging32MB Blackbox
- VideoDJI direct solder
Vishnu 60
- Current60A · 90A burst (7s)
- Input2–6S LiPo
- ProtocolDShot300 / 600
- SensingInbuilt current sensor
- Mounting30.5 × 30.5 · 4mm holes
- Weight14g
VISHNU
60
Four-in-one, 240A continuous. Field tested and proven.
Drop in.
Flash. Fly.
Tuned as a pair and shipped as one stack, with every accessory in the box.
Stack 460 specifications
Brahma F4 flight controller and Vishnu 60 4-in-1 ESC, matched and shipped as one stack on a standard 30.5 × 30.5 mm mount.
Brahma F4 flight controller
| Processor | STM32F405 |
|---|---|
| Gyroscope | BMI270 |
| Barometer | DPS310 |
| On-screen display | Analog OSD |
| Blackbox | 32MB onboard flash |
| USB | Type-C |
| Firmware | Betaflight, INAV, ArduPilot |
| UARTs | 4 |
| I²C | Yes, for compass and external sensors |
| Motor outputs | 8 (M1–M8) |
| 5V output | 2A total |
| 9V output | 2A, for digital VTX |
| 4.5V output | Powered over USB, for the receiver while configuring |
| 3.3V output | For compasses and sensors |
| Digital FPV | DJI direct-solder pads |
| Inputs | RSSI, SBUS |
| Protection | Reverse polarity, USB ESD, power filtering |
| Mounting | 30.5 × 30.5 mm (M4) |
| Dimensions | 37 × 37 × 5 mm |
| Weight | 9 g |
| Made in | India: designed in India, assembled in Bally, West Bengal |
Vishnu 60 ESC
| Type | 4-in-1 ESC |
|---|---|
| Continuous current | 60A per channel, 240A in total |
| Burst current | 90A for 7 seconds |
| Firmware | BLHeli_S or BlueJay (JH_50) |
| Protocol | DShot300 / DShot600 |
| Input | 2–6S LiPo |
| Current sensor | Built in |
| Motors | Maximum draw below 70–80A |
| Flight controller connection | Plug-and-play 8-pin cable |
| Mounting | 30.5 × 30.5 mm, 4 mm holes |
| Dimensions | 46 × 48.8 × 5.7 mm |
| Weight | 14 g |
| Operating temperature | −20 °C to 70 °C |
| Made in | India: designed in India, assembled in Bally, West Bengal |
Book your Stack 460
Message us on WhatsApp. We reply with availability, price and delivery time, and help you pick the right parts for your build.


Stack 460 user manual
Point at any label to see the wire and the part it belongs to. Step through the flashing guides. Zoom in on anything.
Point at a label or a wire to trace it. Click to keep it lit. Double-click to zoom.
Read the Stack 460 manual as text
BRAHMA F4 – Specifications 1/3
| Product Name | Darkmatter® Brahma F4 MK IV |
|---|---|
| Product Category | Flight Controller |
| Processor (MCU) | F4 – STM32F405 |
| Gyroscope (IMU) | BMI270 – 6 Axis |
| Barometer | DPS310 |
| On-Screen Display | AT7456E |
| Blackbox | 32MB Winbond Blackbox |
| USB Port Type | Type-C |
| Supported Flight Controller Firmware | BetaFlight (Default), iNav, Ardupilot |
| Power Input | 2-6S LiPo (Through G, V pins/pads from the 8-pin connector or 8-pads on the bottom side) |
| Mounting | 30.5 X 30.5mm (4mm hole size) |
| Dimensions | 37mm(L) x 37mm(W) x 5mm(H) |
| Weight | 9g |
BRAHMA F4 – Specifications 2/3
| 5V Output | 7 groups of 5V output, four +5V pads and 1 BZ+ pad (used for Buzzer) on front side, and 2x LED 5V pads. The total current load is 2A. |
|---|---|
| 9V Output | 1 groups of 9V output, one +9V pad on front side. The total current load is 2A. |
| 4v5 Output | 1 4.5V output, 500mA from USB to connect receiver or other peripherals |
| 3.3V Output | Supported. Up to 500mA current load. |
| Traditional BetaFlight LED Pad | Supported. 5V, G and LED pads on the bottom side. Used for WS2812 LED controlled by BetaFlight firmware. |
| Buzzer | BZ+ and BZ- pad used for 5V Buzzer |
| Motors Supported | 8 Motors |
| ESC Signal | M1 - M8 on bottom side |
| DJI Air Unit Connection Way | Supported: Direct soldering |
BRAHMA F4 – Specifications 3/3
| BOOT Button | Supported. Press and hold BOOT button and power the FC on at the same time will force the FC to enter DFU mode, this is for firmware flashing when the FC gets bricked. |
|---|---|
| RSSI Input | Supported. Named as RSI on the front side. |
| SmartPort | Use any TX pad of UART for the SmartPort feature. |
| UART | 4 sets(UART1, UART3(For ESC Telemetry), UART4, UART6) |
| ESC Telemetry UART | R3(UART3) |
| I2C | Supported. SDA & SCL pads on front side. Used for magnetometer, sonar, etc. |
| BETAFLIGHT TARGET NAME | BRAHMA_F405 |
| OPERATING TEMPERATURE | -10°C TO 55°C.. |
| COUNTRY OF ORIGIN | INDIA |
VISHNU 60 – Specifications
| Product Name | Darkmatter® Vishnu 60 |
|---|---|
| Product Category | ELECTRONIC SPEED CONTROLLER (ESC) |
| Firmware | BLHeli_S /BlueJay ( JH_50 ) |
| Burst Current | 90A (7 Seconds) |
| Continuous Current | 60A x 4 = 240A |
| ESC Protocol | DSHOT300/600 |
| Power Input | 2-6S BAT | IMPORTANT Please solder the low ESR capacitor between VBAT "+" and" -", and the VBAT “-” should be connected to the -ve side of the capacitor only. |
| Power Output | VBAT |
| Current Sensor | Inbuilt |
| Mounting | 30.5 x 30.5mm, 4mm hole size |
| Dimensions | 46 * 48.8 * 5.7mm |
| Weight | 14g |
| Supported Motors | PLEASE CHECK MOTOR MAX CURRENT DRAW FROM MOTOR MANUFACTURER’S MANUAL, SHOULD BE BELOW 70-80A. PROVIDED YOU ARE NOT PLANNING TO FLY ON 100% THROTTLE FOR 100% OF THE TIME WITH THE LARGEST PROP SUPPORTED BY THE MOTOR, IF THAT'S THE CASE LOOK FOR 60A OR BELOW. |
| Operating Temperature | -20 to 70 Degree Celsius |
| COUNTRY OF ORIGIN | INDIA |
DIMENSIONS
Front · Back · 30.5MM · 4MM · 37MM · 30MM · Side · 5MM · 1.6MM
DIMENSIONS
Front · Back · 30.5MM · 4MM · 46MM · 48.8MM
Flight Controller Layout
MCU - STM332F405 · OSD Chip · Gyro – BMI270 · Baro – DPS310 · Boot Button · 8Pin ESC Connector · Type C Port · UART #6 · VTX · UART#1 · Buzzer · FPV CAM · ESC Solder Pads M1-M4) · 9V/2A BEC · 5V/2A BEC · LED Strip · 32MB Blackbox · Reverse Polarity Protection · USB ESD Protection · Dual 3.3V LDO · Status LEDs · ESC Solder Pads (M5-M8) · UART #4 · UART #3 · I2C · 4V5 PAD · RSSI · SBUS
Flight Controller – STANDARD CONNECTION PROTOCOL
GPS & Compass · FPV CAM · ESC Solder Pads · LED Strip · T6 · R6 · 5V · SCL · SDA · B+ · B- · CAM · VTX · VTX · 9V · IBUS RECEIVER · ELRS RECEIVER · SBUS RECEIVER · SBUS · RX · TX · Buzzer · FC Status · 3.3v IMU · 3.3v FC · 5v · LED INDICATORS
4 in 1 ESC Plug and Play Connection
CURRENT · MOTOR 1 · MOTOR 2 · MOTOR 3 · MOTOR 4 · GROUND · VOLTAGE · TELEMETRY · Motor 2 · Motor 4 · Motor 3 · Motor 1 · BETAFLIGHT STANDARD CONNECTOR
4 in 1 ESC Direct Soldering Connection
Motor 2 · Motor 4 · Motor 3 · Motor 1 · CURRENT · MOTOR 4 · MOTOR 3 · MOTOR 2 · MOTOR 1 · GROUND · VOLTAGE
4 in 1 ESC Motor Connection Numbering
Motor 2 · Motor 4 · Motor 3 · Motor 1 · THIS SIDE FACING UP · THIS SIDE FACING DOWN
2 x 4 in 1 ESC Direct Soldering Connection For 8 Motors
MOTOR 8 · MOTOR 7 · MOTOR 6 · MOTOR 5 · GROUND · BATTERY
Single ESCs Direct Soldering Connection For 8 Motors
CONNECT BRAHMA F4 WITH IBUS RECEIVER
IBUS RECEIVER · *IF USING BETAFLIGHT KINDLY REFLASH WITH IBUS PROTOCOL SELECTED AND THEN TURN ON Serial Rx ON UART 1
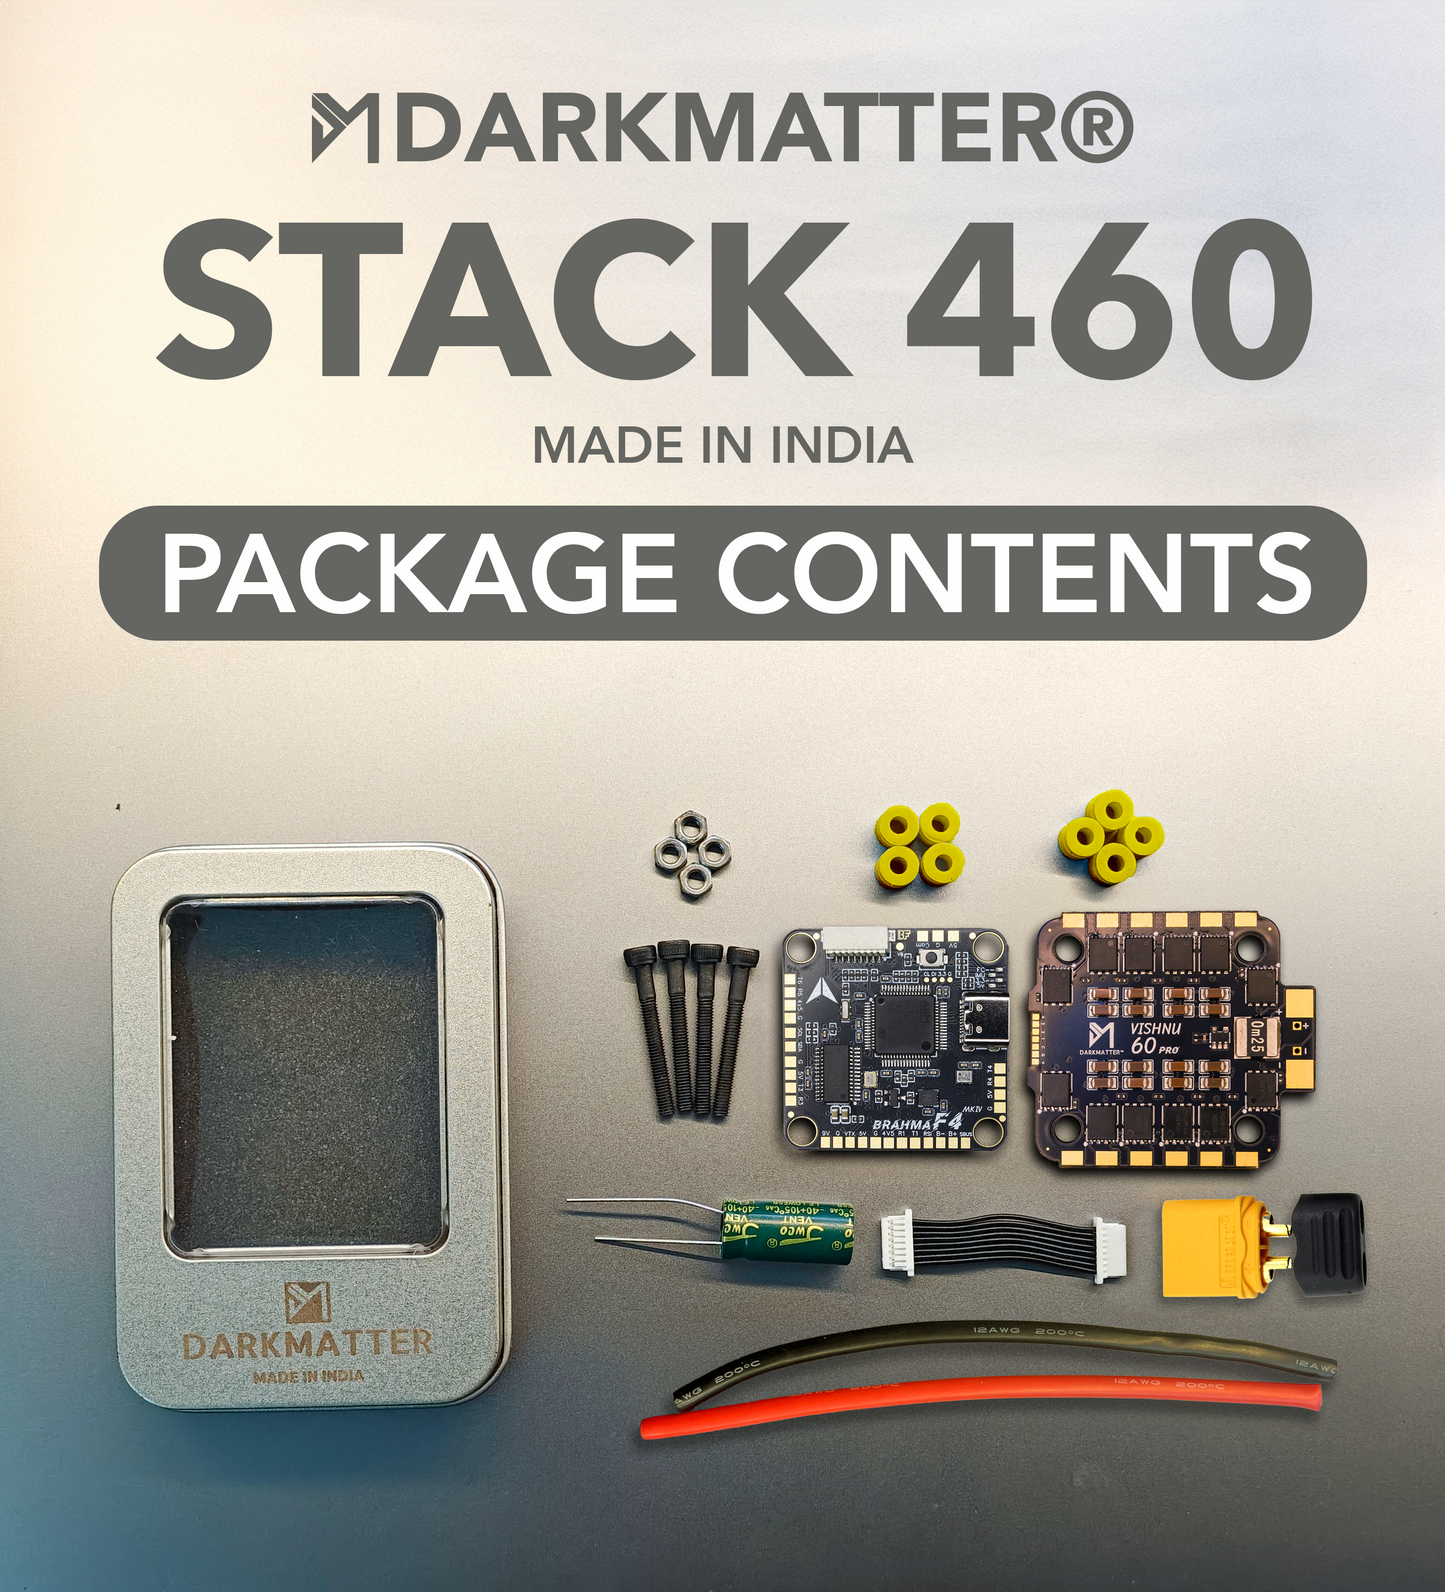
STACK 460 – Package Contents
• 1x Brahma F4 • 1x Vishnu 60 • 1x 8Pin ESC FC Connector Cable • 8x Grommets (Gummies) • 1x 1000uF Low ESR Capacitor • 1x XT60 Battery Connector Plug • 1x 12AWG Wire for Battery Connection • 4x M3 25mm Screws • 4x M3 Bolts • 1x Tin Container Box
HOW TO FLASH ARDUPILOT ON BRAHMA F4 (1/2)
- PRESS AND HOLD THE BOOT BUTTON and connect to PC and open STM32 Cube Programmer
- CLICK ON CONNECT Remember the blue option will be USB
- Open the second menu item -> Erasing & Programming
- Before flashing, we need to do Full Chip Erase. Press the Full chip erase and wait for the log to ask you disconnect device, after which you disconnect the device
- Click on connect again to connect to the FC
- Go to the first tab and then click on OPEN FILE and load the firmware by downloading it from the QR Code below
- Click on the Download button once the file has been loaded and then wait for the firmware flashing to complete
HOW TO FLASH ARDUPILOT ON BRAHMA F4 (2/2)
- Open the Mission Planner application
- Select the COM port which shows up as Ardupilot and then click on connect
HOW TO CONNECT HERELINK WITH BRAHMA F4
Herelink SBUS Herelink ‘S Bus out 1’ to BRAHMA H4 RX6 (Serial 4) Herelink GRD to a BRAHMA F4 GND SERIAL4_PROTOCOL=23 (RCIN) SERIAL4_OPTIONS=3 (SwapTXRX - RX6 becomes TX6). Herelink UART connector Herelink RXD to the BRAHMA F4 TX1 (Serial 4) Herelink TXD to the BRAHMA F4 RX1 (Serial 4) Set SERIAL4_PROTOCOL= 2
HOW TO CONNECT COMPANION COMPUTER (PI) WITH BRAHMA F4
BRAHMA SETUP : LET'S USE THE UART 4 IN BRAHMA TO CONNECT TO THE RASPBERRY PI, YOU CAN REFER TO THE CONNECTION DIAGRAM ON THE SIDE FOR CONNECTING THEM THEN IN MISSION PLANNER, GO TO FULL PARAMETER LIST SET THE FOLLOWING: • SERIAL4_PROTOCOL = 2 • SERIAL4_BAUD = 921 COMPANION COMPUTER SETUP: YOU HAVE TO ENABLE SERIAL BY: > sudo raspi-config THEN, Go to: • Interface Options → Serial Port • “Login shell over serial?” → No • “Enable serial hardware?” → Yes · You can use any model of Pi
HOW TO FLASH BETAFLIGHT ON BRAHMA F4 (1/2)
- PRESS AND HOLD THE BOOT BUTTON and connect to PC and open BETAFLIGHT CONFIGURATOR
- ONCE IN DFU CLICK ON UPDATE FIRMWARE
- SELECT BOARD = BRAHMA_F405 - MAKE SURE FULL CHIP ERASE IS ON
- SELECT THE PROTOCOL OF THE RADIO YOU ARE USING
- Include Magnetometers if you plan on using one
- Select the Motor Procol : Let is be DSHOT if you are using VISHNU, else select accordingly, the other single ESCs available on the market mostly use PWM
- CLICK ON LOAD Load Firmware [Online] and wait for it to build and download.
- CLICK ON LOAD Flash Firmware
HOW TO FLASH BETAFLIGHT ON BRAHMA F4 (2/2)
- WAIT A BIT FOR THE ERASING AND FLASHING TO COMPLETE
- CLICK ON CLOSE
- Enter the following in the command box, and enter save at last to save and reboot Click here to download the txt file which you can copy paste
- CLICK ON CLI FROM THE LEFT HAND SIDE MENU
HOW TO FLASH INAV ON BRAHMA F4 (1/2)
- ONCE IN DFU CLICK ON FIRMWARE FLASHER
- PRESS AND HOLD THE BOOT BUTTON and connect to PC and open INAV CONFIGURATOR
- CLICK ON LOAD FIRMWARE LOCAL
- SCAN TO DOWNLOAD THE HEX FILE AND SELECT THAT
- CLICK ON LOAD FLASH FIRMWARE
- WAIT A BIT FOR THE ERASING AND FLASHING TO COMPLETE
HOW TO FLASH INAV ON BRAHMA F4 (2/2)
- SELECT THE TYPE OF CRAFT YOU ARE MAKING
- SELECT THE UART & THE RECEIVER PROTOCOL FOR RX
- SELECT THE UART PORT FOR GPS
• Warranty Period: The STACK 460 comes with a 6-month warranty for any manufacturing defects from the date of purchase. • Proof of Purchase: Please retain and provide a copy of the purchase invoice for warranty claims. • Exclusions: The warranty does not cover : • Any physical damage to the product due to usage like water damage, tampered components • Burnt circuit due to wrong wiring or overloading. • Burning ESC due to spinning motors without propellers beyond 15% during initial testing for motor direction. • Burning ESC due to arming the drone without propellers in Angle mode and expecting it to stop spinning by lowering the throttle, which it will not, as the FC is trying hard to level but it can't, as you guessed it, there is no propeller. • Warranty Process: If a claim is made within the warranty period, we will examine the PCB for physical damage and the points stated above. If the product is eligible, we will provide a replacement at no additional cost and support you for your build. Your satisfaction and product performance are our top priorities. For any warranty-related inquiries, please contact us at +918017193277.
• Warranty Period: The STACK 460 comes with a 6-month warranty for any manufacturing defects from the date of purchase. • Proof of Purchase: Please retain and provide a copy of the purchase invoice for warranty claims. • Exclusions: The warranty does not cover : • Any physical damage to the product due to usage like water damage, tampered components • Burnt circuit due to wrong wiring or overloading. • Burning ESC due to spinning motors without propellers beyond 15% during initial testing for motor direction. • Burning ESC due to arming the drone without propellers in Angle mode and expecting it to stop spinning by lowering the throttle, which it will not, as the FC is trying hard to level but it can't, as you guessed it, there is no propeller. • Warranty Process: If a claim is made within the warranty period, we will examine the PCB for physical damage and the points stated above. If the product is eligible, we will provide a replacement at no additional cost and support you for your build. Your satisfaction and product performance are our top priorities. For any warranty-related inquiries, please contact us at +918017193277. · STACK 460 - 6 Months Warranty